Main Page | Namespace List | Class Hierarchy | Alphabetical List | Class List | File List | Namespace Members | Class Members | File Members | Related Pages

GT2004BasicBehaviorEvolveOmniParameters Class Reference

A BasicBehavior for walking forward or backward following a certain parcour as well as changing walking parameters according to the fitness measured in the last parcour walk This Basic Behavior needs a walking engine that does not switch parameters according to the MotionRequest (like InvKin:GT2003 and GT2004), but a non-switching one (like InvKin:FF). More...

#include <GT2004EvolutionBasicBehaviors.h>

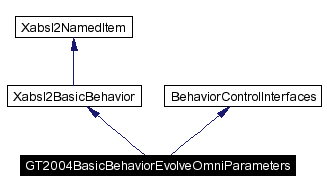
Inheritance diagram for GT2004BasicBehaviorEvolveOmniParameters:
Inheritance graph
[legend]
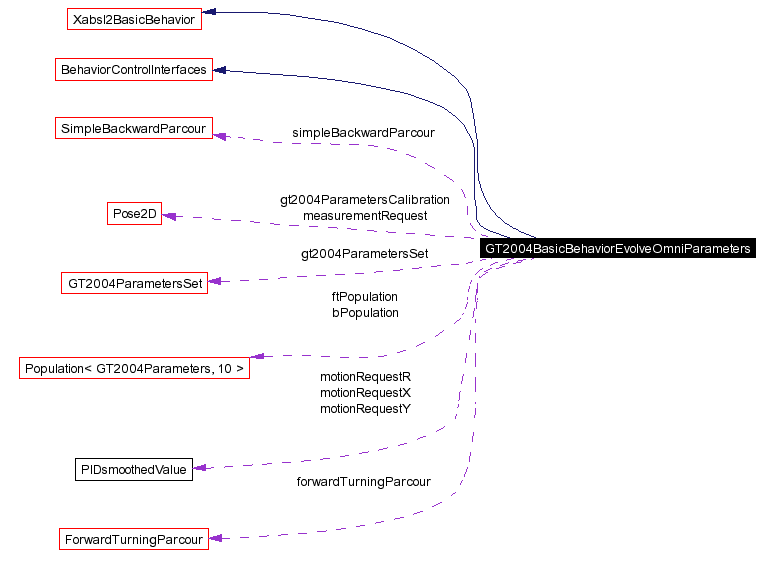
Collaboration diagram for GT2004BasicBehaviorEvolveOmniParameters:

Collaboration graph
[legend]
List of all members.

Public Member Functions

 GT2004BasicBehaviorEvolveOmniParameters (const BehaviorControlInterfaces &interfaces, Xabsl2ErrorHandler &errorHandler, GT2004ParametersSet &gt2004ParametersSet, Pose2D *gt2004ParametersCalibration, int &gt2004CurrentIndex, Pose2D &measurementRequest, int &evolutionMode)
virtual void execute ()
 Executes the basic behavior.


Private Attributes

Population< GT2004Parameters, 10 > ftPopulation
 a Polpulation of WalkingParameters

Population< GT2004Parameters, 10 > bPopulation
double mode
 specifies whether the robot should walk forward or backward or parameters should be changed

int lastMode
ForwardTurningParcour forwardTurningParcour
SimpleBackwardParcour simpleBackwardParcour
PIDsmoothedValue motionRequestX
PIDsmoothedValue motionRequestY
PIDsmoothedValue motionRequestR
GT2004ParametersSet & gt2004ParametersSet
 GT2004 Evolution stuff.

Pose2D * gt2004ParametersCalibration
int & gt2004CurrentIndex
Pose2D & measurementRequest
int & evolutionMode

Detailed Description

A BasicBehavior for walking forward or backward following a certain parcour as well as changing walking parameters according to the fitness measured in the last parcour walk This Basic Behavior needs a walking engine that does not switch parameters according to the MotionRequest (like InvKin:GT2003 and GT2004), but a non-switching one (like InvKin:FF).

Author:
Uwe Düffert

Definition at line 139 of file GT2004EvolutionBasicBehaviors.h.


Constructor & Destructor Documentation

GT2004BasicBehaviorEvolveOmniParameters::GT2004BasicBehaviorEvolveOmniParameters (  const BehaviorControlInterfaces &  interfaces,
Xabsl2ErrorHandler &  errorHandler,
GT2004ParametersSet &  gt2004ParametersSet,
Pose2D *  gt2004ParametersCalibration,
int &  gt2004CurrentIndex,
Pose2D &  measurementRequest,
int &  evolutionMode
)  [inline]
 

Definition at line 147 of file GT2004EvolutionBasicBehaviors.h.

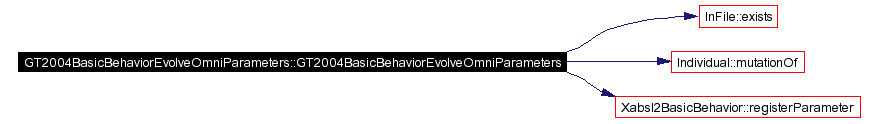
References bPopulation, InFile::exists(), ftPopulation, GT2004Parameters::index, Population< GT2004Parameters, 10 >::individual, lastMode, motionRequestR, motionRequestX, motionRequestY, Individual::mutationOf(), pi, and Xabsl2BasicBehavior::registerParameter().

Here is the call graph for this function:

Member Function Documentation

void GT2004BasicBehaviorEvolveOmniParameters::execute (   )  [virtual]
 

Executes the basic behavior.

Implements Xabsl2BasicBehavior.

Definition at line 27 of file GT2004EvolutionBasicBehaviors.cpp.

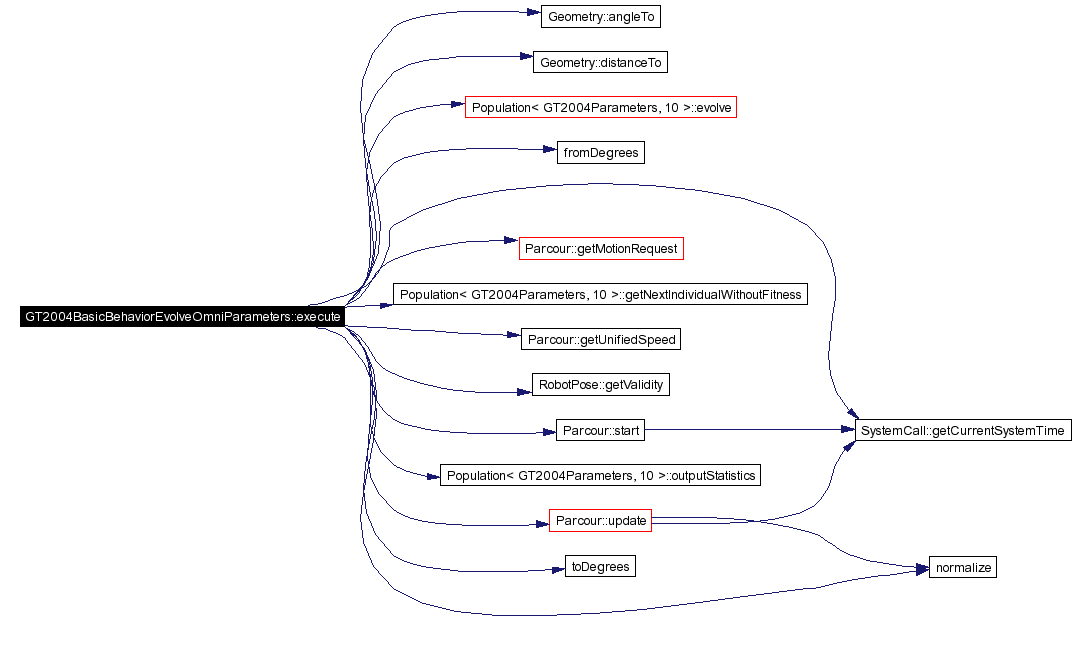
References RobotState::acceleration, Geometry::angleTo(), bPopulation, Geometry::distanceTo(), Population< GT2004Parameters, 10 >::evolve(), Individual::fitness, forwardTurningParcour, fromDegrees(), ftPopulation, SystemCall::getCurrentSystemTime(), Parcour::getMotionRequest(), Population< GT2004Parameters, 10 >::getNextIndividualWithoutFitness(), Parcour::getUnifiedSpeed(), RobotPose::getValidity(), idGT2004Parameters, idInvKinWalkingParameters, idText, lastMode, MotionRequest::motionType, normalize(), OUTPUT, Population< GT2004Parameters, 10 >::outputStatistics(), Pose2D::rotation, simpleBackwardParcour, Parcour::start(), toDegrees(), Pose2D::translation, Parcour::update(), MotionRequest::updateRP, WalkRequest::walkParams, MotionRequest::walkRequest, WalkRequest::walkType, Vector2< double >::x, and Vector2< double >::y.

Here is the call graph for this function:

Member Data Documentation

Population<GT2004Parameters,10> GT2004BasicBehaviorEvolveOmniParameters::ftPopulation [private]
 

a Polpulation of WalkingParameters

Definition at line 201 of file GT2004EvolutionBasicBehaviors.h.

Referenced by execute(), and GT2004BasicBehaviorEvolveOmniParameters().

Population<GT2004Parameters,10> GT2004BasicBehaviorEvolveOmniParameters::bPopulation [private]
 

Definition at line 202 of file GT2004EvolutionBasicBehaviors.h.

Referenced by execute(), and GT2004BasicBehaviorEvolveOmniParameters().

double GT2004BasicBehaviorEvolveOmniParameters::mode [private]
 

specifies whether the robot should walk forward or backward or parameters should be changed

Definition at line 205 of file GT2004EvolutionBasicBehaviors.h.

int GT2004BasicBehaviorEvolveOmniParameters::lastMode [private]
 

Definition at line 206 of file GT2004EvolutionBasicBehaviors.h.

Referenced by execute(), and GT2004BasicBehaviorEvolveOmniParameters().

ForwardTurningParcour GT2004BasicBehaviorEvolveOmniParameters::forwardTurningParcour [private]
 

Definition at line 208 of file GT2004EvolutionBasicBehaviors.h.

Referenced by execute().

SimpleBackwardParcour GT2004BasicBehaviorEvolveOmniParameters::simpleBackwardParcour [private]
 

Definition at line 209 of file GT2004EvolutionBasicBehaviors.h.

Referenced by execute().

PIDsmoothedValue GT2004BasicBehaviorEvolveOmniParameters::motionRequestX [private]
 

Definition at line 210 of file GT2004EvolutionBasicBehaviors.h.

Referenced by GT2004BasicBehaviorEvolveOmniParameters().

PIDsmoothedValue GT2004BasicBehaviorEvolveOmniParameters::motionRequestY [private]
 

Definition at line 210 of file GT2004EvolutionBasicBehaviors.h.

Referenced by GT2004BasicBehaviorEvolveOmniParameters().

PIDsmoothedValue GT2004BasicBehaviorEvolveOmniParameters::motionRequestR [private]
 

Definition at line 210 of file GT2004EvolutionBasicBehaviors.h.

Referenced by GT2004BasicBehaviorEvolveOmniParameters().

GT2004ParametersSet& GT2004BasicBehaviorEvolveOmniParameters::gt2004ParametersSet [private]
 

GT2004 Evolution stuff.

Definition at line 213 of file GT2004EvolutionBasicBehaviors.h.

Pose2D* GT2004BasicBehaviorEvolveOmniParameters::gt2004ParametersCalibration [private]
 

Definition at line 214 of file GT2004EvolutionBasicBehaviors.h.

int& GT2004BasicBehaviorEvolveOmniParameters::gt2004CurrentIndex [private]
 

Definition at line 215 of file GT2004EvolutionBasicBehaviors.h.

Pose2D& GT2004BasicBehaviorEvolveOmniParameters::measurementRequest [private]
 

Definition at line 216 of file GT2004EvolutionBasicBehaviors.h.

int& GT2004BasicBehaviorEvolveOmniParameters::evolutionMode [private]
 

Definition at line 217 of file GT2004EvolutionBasicBehaviors.h.


The documentation for this class was generated from the following files:
Generated on Thu Sep 23 20:06:46 2004 for GT2004 by doxygen 1.3.6